Systems & AI Engineer

I build software for devices, simulations and AI tools.

I’m Louijie, a systems and AI engineer with 14+ years of experience. Here you can explore my public code, working examples and the decisions behind them.

View engineering background →

Featured project / Omniweft

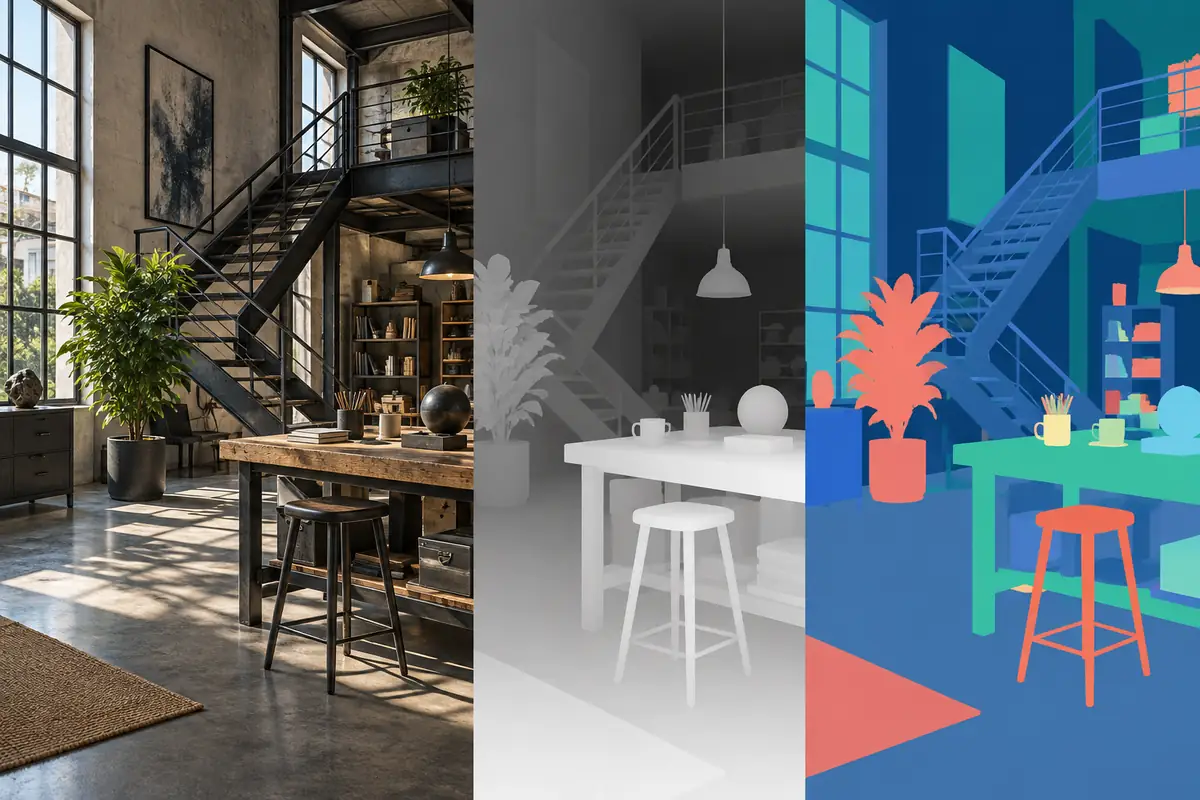
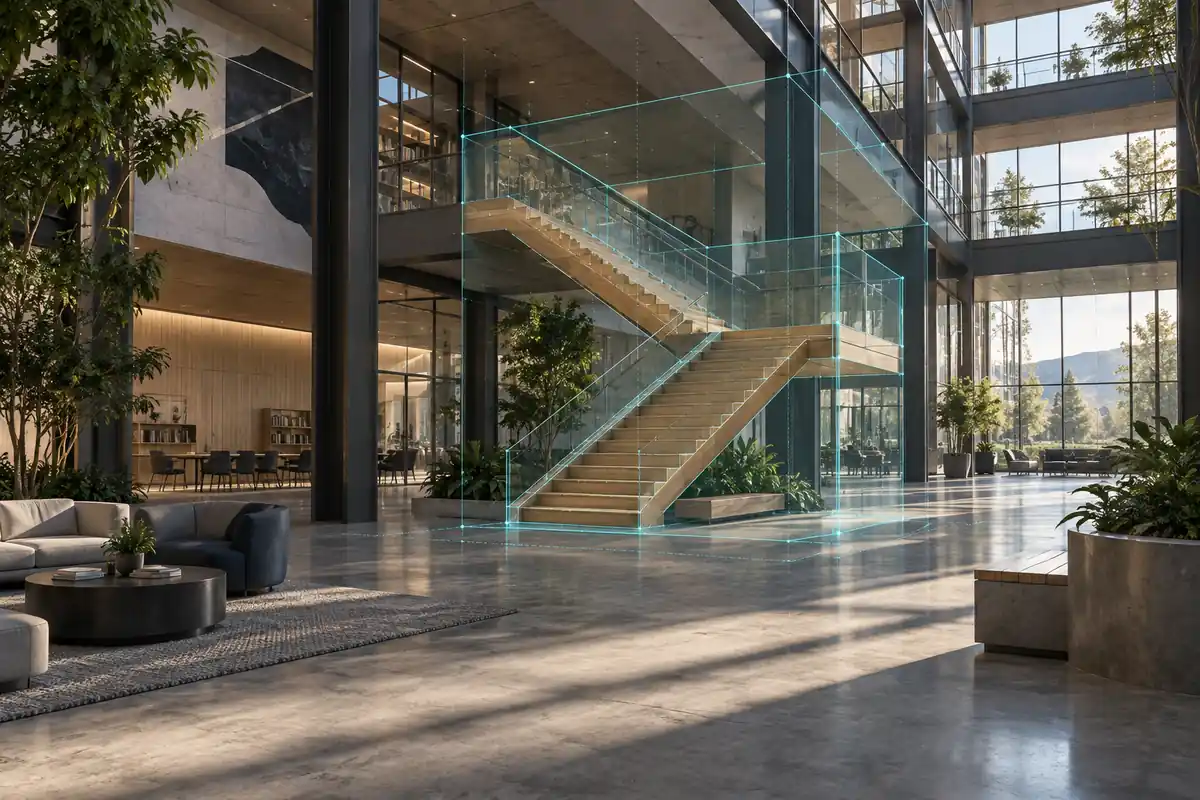
A sunlit architectural world with teal editing guides around a staircase, expressing programmable world-building.
Programmable worlds, with changes you can inspect.Explore in 3D →

Evidence operations desk

Recent work. Results and limits together.

A dated source review, not a live dashboard. Open each file to inspect the retained output and the question it leaves open.

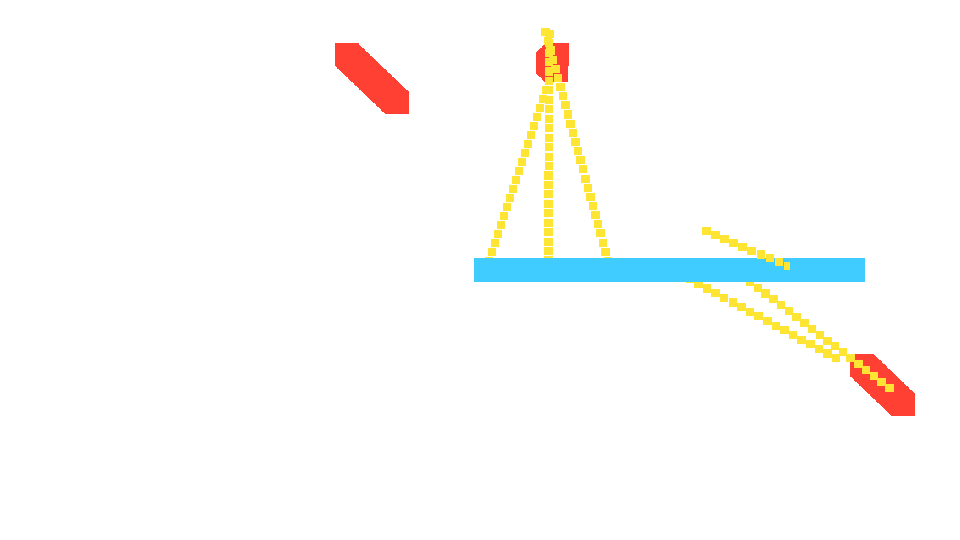
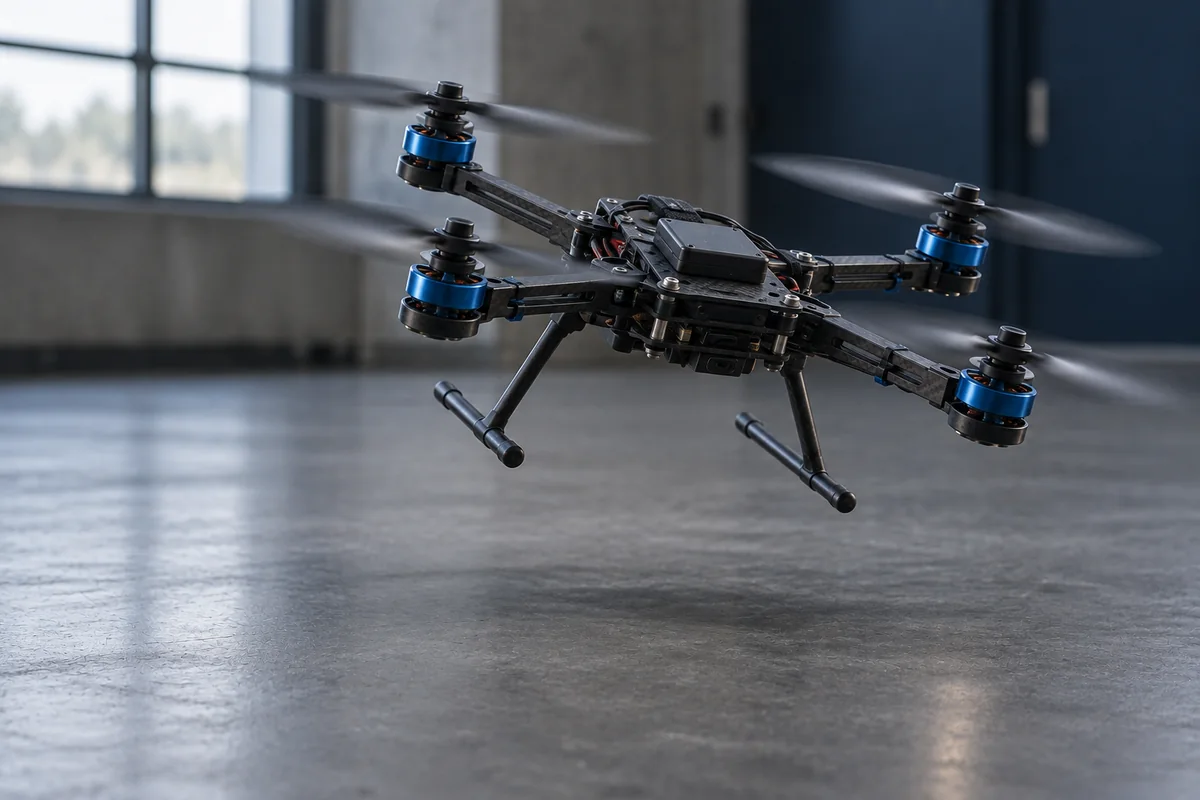
AeroLoop / PR #21

Outage recovery

500 ms recovers in the tested profiles. Longer gaps expose the boundary.

Sensor outage study · accepted: false
250 ms
Pass
3/3 missions
500 ms
Pass
3/3 missions
1 s
Mixed
2/3 missions
2 s
Fail
0/3 missions

Held-feedback baseline, seeds 0/1/2. Mixed means some mission passes; all one-second paired checks fail. This is not a safe-duration limit.

Open limit. Later prediction and landing-guard studies still retain accepted: false.

Read the engineering story →

Inspect source ↗

Omniweft / PR #22 / PR-015

Worker recovery

Workers can fail without gaining mutation authority. Explicit retry can recover the original receipt.

Retained worker fixture · CPU / seed 7
PhaseStatusWorld revision
timeouttimed_out0
cancelledcancelled0
crashedcrashed0
supersededsuperseded0

Recorded statuses from the public archive. Prevented proposals leave the world at revision zero.

Open limit. The parent and volatile policy host must survive. No OS sandbox claim.

Read the engineering story →

Inspect source ↗

LudoWeave Engine / M244 / PR #262

Verified replay

Pause, step, seek and resume with visible tick and playback status through M244.

Retained Clockwork Arena frame with obstacles and moving entities
Earlier Clockwork Arena capture. The M244 status panel is documented in the current source, not shown in this frame.

Open limit. Presentation controls do not change recorded input. Seeking has no latency guarantee.

Read the engineering story →

Inspect source ↗

Selected public work

What the projects actually do.

Follow a recorded flight, inspect a saved room or explore what an AI tool sees. Each project links the output to its code, decisions and current limits.

View all public work
Look closer: four captured views from Cogniform

A real example from Cogniform

What can software learn from a cube?

A person can look at a picture and recognize an object. An AI tool also needs information it can work with: distance, surface direction and object identity.

Cogniform produces these four views of the same scene, so a tool can connect what it sees to the object it can change.

See the example and how it was checked
  • Color observation of the reference cube against a dark backgroundAppearance
  • Grayscale depth observation of the same reference cubeDistance
  • Colored faces showing the reference cube's world-space surface directionsSurface direction
  • Single palette-colored silhouette identifying the reference cubeObject identity
Actual output from a small local test. Each original image is 64 × 64 pixels, enlarged here for inspection. Captured .

Start with your engineering interests →

A note from Louijie

The thread through my work.

Louijie Compo

I work across the boundaries between physical devices, software platforms and applied AI. I make interfaces explicit, test assumptions early and carry ideas from architecture into working implementation.

These projects give you a way into that work: look at a frame, follow a request, or inspect what happens when a change is rejected. Pick the part that makes you curious.

Engineering journal

Writing & ideas.

All writing

Latest project updates →

Professional connection

Bring clarity to a complex system.

For conversations about systems, architecture, applied AI, or carrying technical direction into implementation.

Get in touch